Ask most people how a damper is tuned and they will picture an engineer at a test track, adjusting something until the car feels right. That moment is real, and it is still where sign-off happens. But by the time the car turns a wheel, most of the decisions have already been made. Marcin Knapczyk, Chief Engineer at BWI Group, explains the process of damper tuning.
Where does tuning actually begin?
A long way from the car. It all starts with the customer and what they want to achieve. We normally work to a statement of requirements the size of a small book. It defines what the product needs to do and therefore what needs to be tested: durability requirements, hot and cold temperature ranges, all the different conditions the vehicle will meet in its life. Alongside that sits the performance target.
So the requirements are set. How does the system get into the vehicle?
Every project starts with integrating the system into the customer’s architecture. For semi-active system like MagneRide, that means aligning our software with their control environment and making sure everything communicates properly. Only once the system is operational do we begin calibration, adjusting control parameters to match the ride and handling characteristics the customer is after.
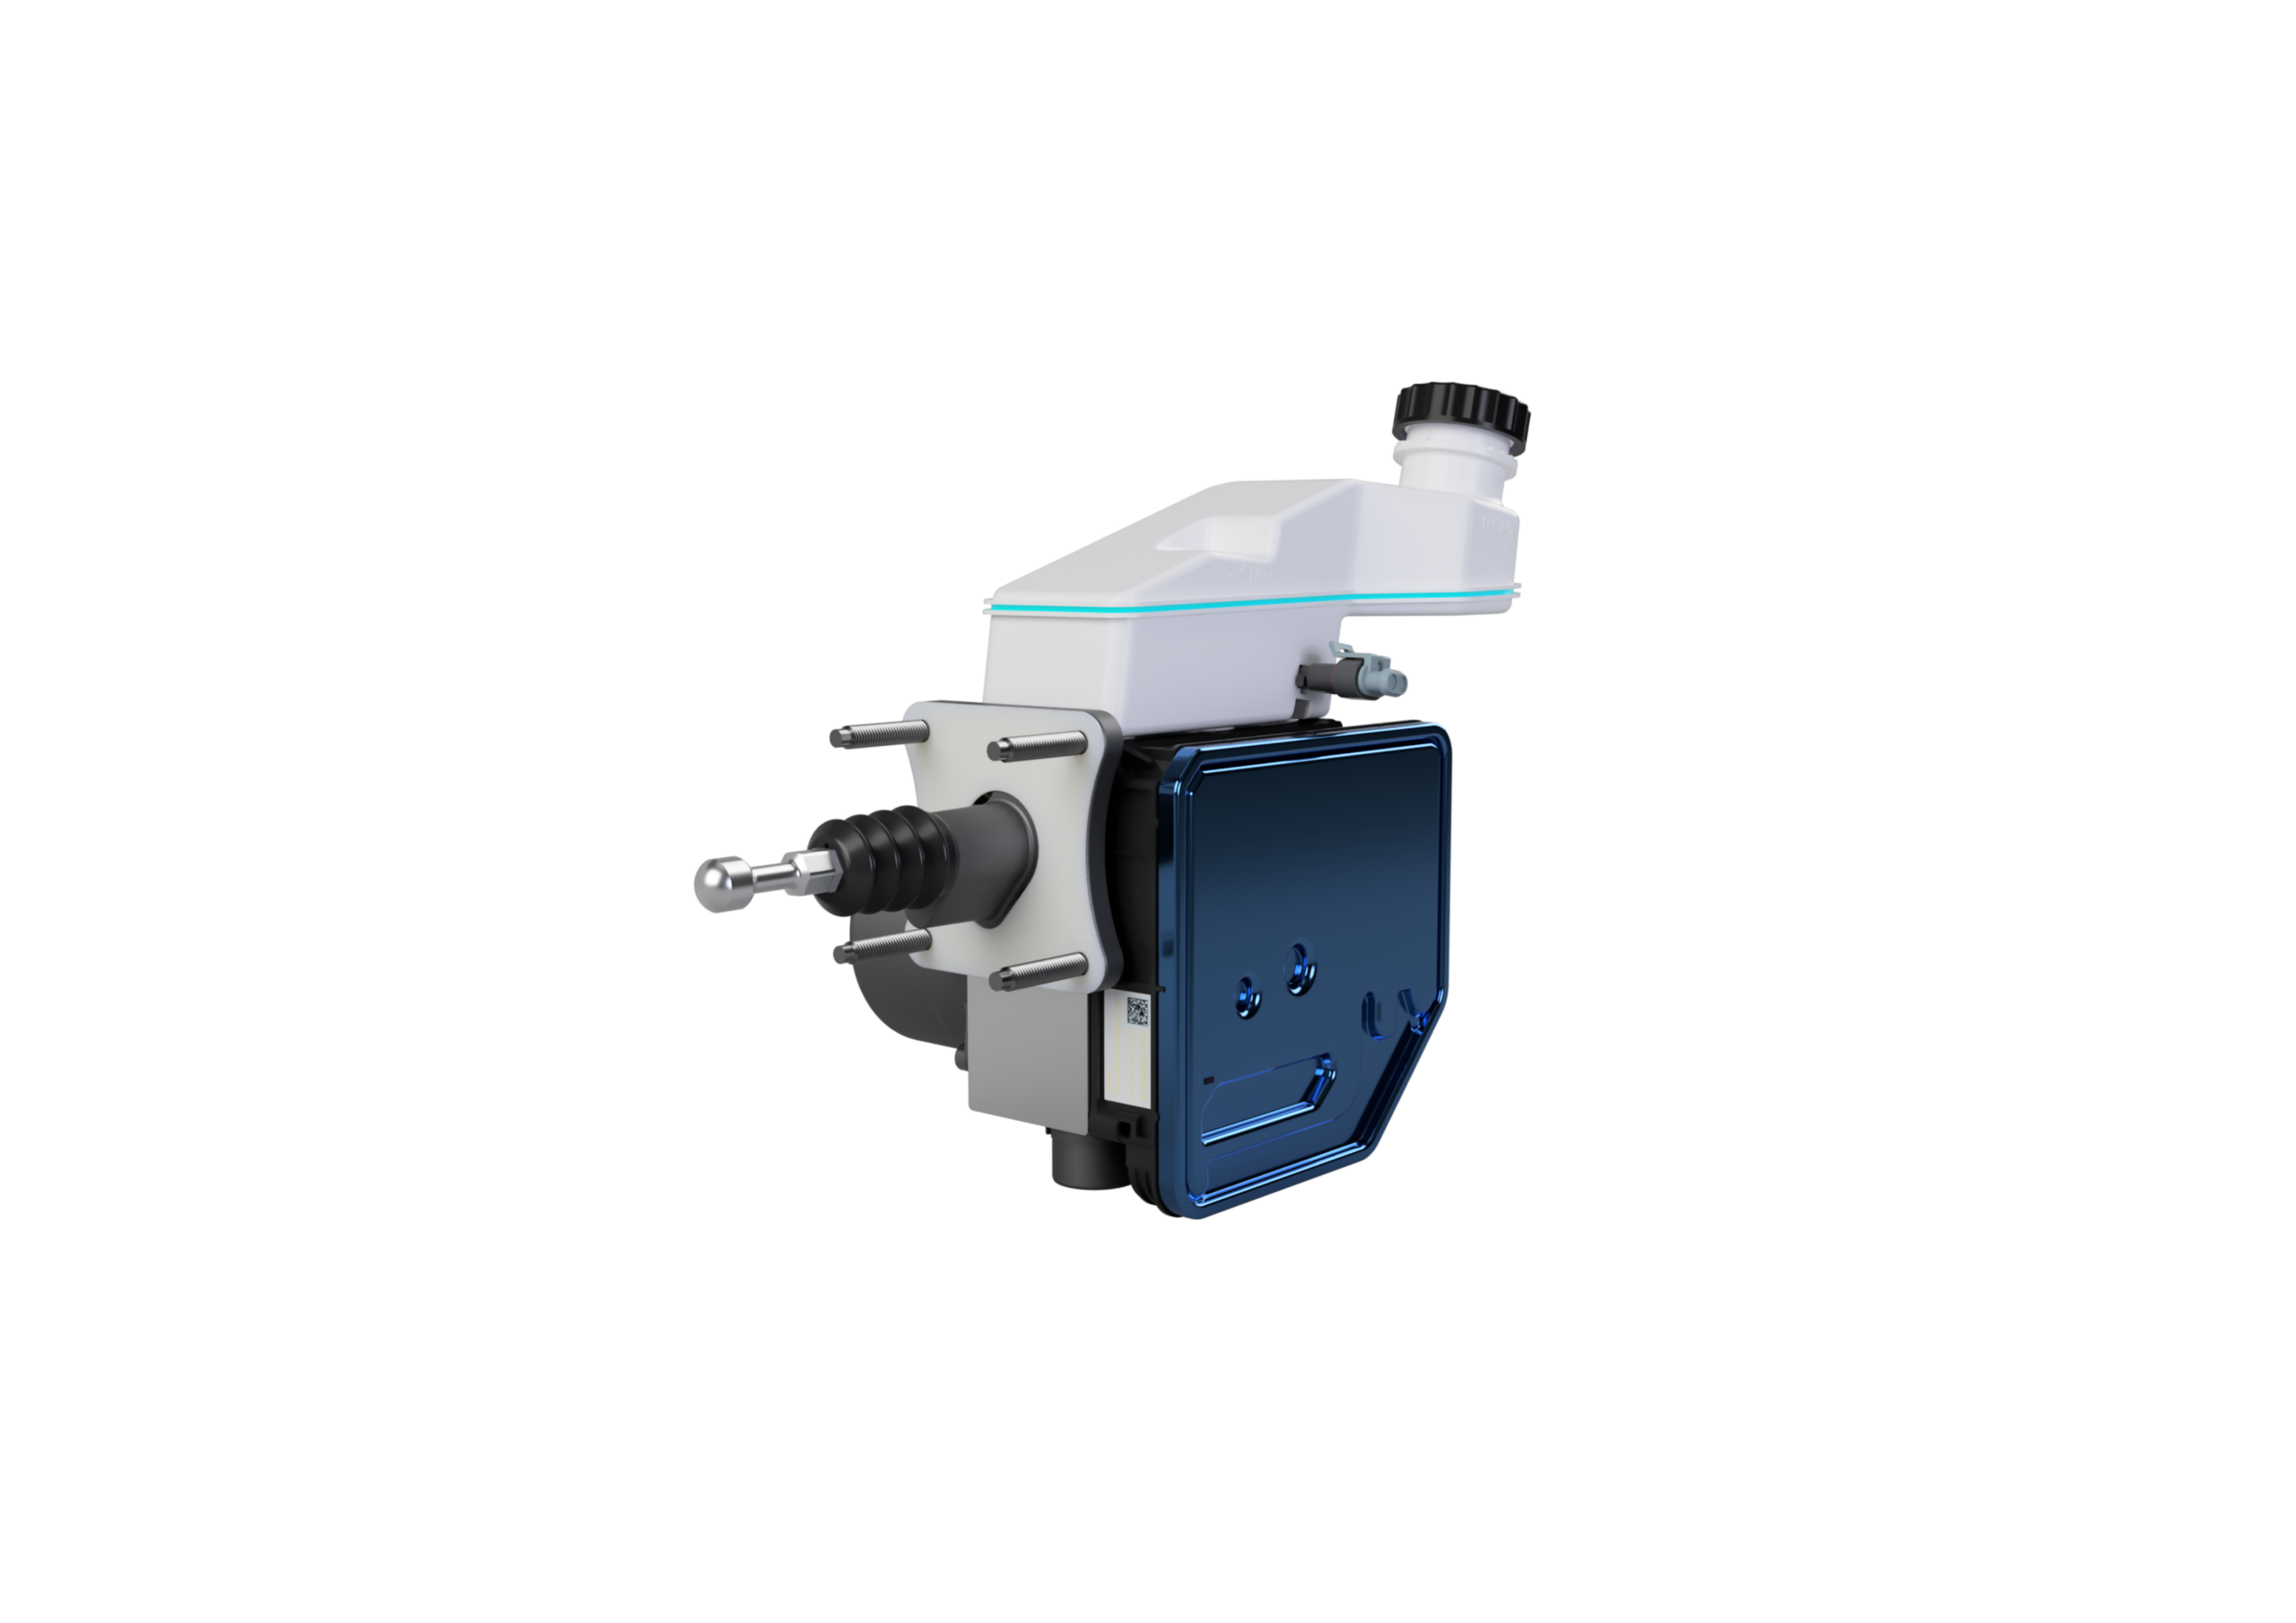
We have become more modular about how that works. We can supply a complete MagneRide system, including the dampers, sensors, ECUs and software, or just the individual components required. Some customers want full system delivery and tuning support. Others prefer to embed our control algorithms into their own ECUs.
Once you are up and running, what are you actually looking for?
We refine the system through real-world testing, evaluating ride comfort, body control, noise and vibration levels and overall vehicle dynamics, and we work towards whatever the customer wants the car to be, whether that is sharp handling for a performance model or a more composed ride in an electric SUV.
Underneath those targets are two things we have to control at once. Primary ride is body movement. Secondary ride is wheel control. MagneRide can respond in just a few milliseconds, which allows us to control both precisely. On a challenging surface such as an uneven country road, that responsiveness makes a real difference: we can maintain strong body control without introducing harshness from the wheels. Other systems often reach a point where they have to increase damping to control the body, and that leads to an overly stiff ride.
When the driver comes back with feedback, how quickly can you act on it?
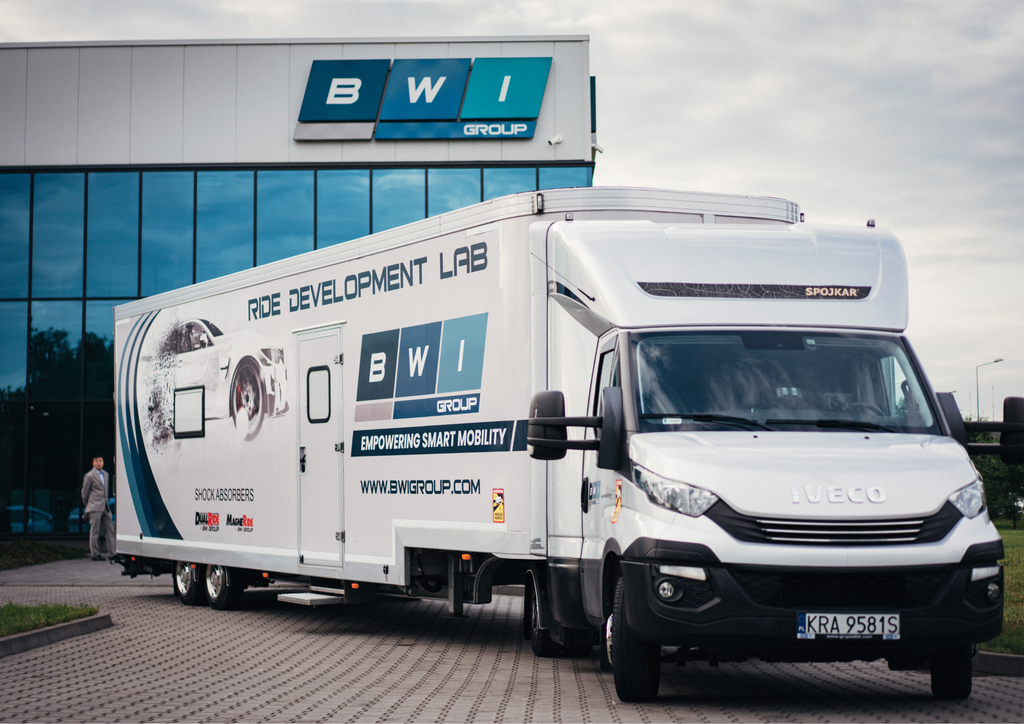
That is what magnetorheological damping changed. Traditional passive systems use valves, which often require physical hardware changes during development. You are manufacturing and swapping out multiple sets of valves to refine the tuning, and that is time-consuming and resource-intensive. Ride Van, our mobile laboratory, travels and resides at a customer’s site (proving ground) where physical changes are made
With MagneRide we do not need to change any hardware during tuning. The damping force is controlled digitally through software, so our ride engineers can make changes directly from a laptop. That gives us much more agility in development, reduces cost and speeds up the entire calibration process.
How much of the final judgement is still subjective?
Subjective evaluation is a critical part of sign-off, and it is not going away. The complexity of modern vehicles, with all the subsystems in a modern chassis, makes it extremely difficult to do everything virtually, and an expert driver can evaluate the car across many conditions in a very short time. In subjective evaluation your body is the sensor, and you cannot simulate that. Even with all the AI we have now, it is difficult to describe what we are looking for.
How do you know when a tune is finished?
The bench test verifies durability and, in a more limited way, performance. The vehicle is where we verify that performance and define the nominal damper that is then reproduced in series production. After the ride session we have a master set, which is the evidence of what the customer tested.
How is simulation changing the shape of all this?
One of the biggest impacts is the reduction in the number of physical prototypes. One OEM told us they can now build ten times fewer test vehicles for a new vehicle generation than before, and a prototype car is extraordinarily expensive. The downside is that there is less access to prototype vehicles, which in turn encourages more virtual testing. It follows through to us as well: fewer prototype vehicles mean fewer prototype dampers to produce. Where simulation helps us most is FEA and CFD, predicting failures and avoiding them, which reduces the number of samples required.
So where does damper development go next?
It will continue to move towards bench testing. Using hardware in the loop to extend virtual testing and validate your models is much more cost effective and quicker than track testing, and you want the product to be as mature as possible before progressing to in-vehicle testing. But there will always be a need for physical vehicle dynamics testing.
The other direction is software. As EV adoption increases, expectations around noise and ride quality rise with it. Without engine noise to mask imperfections, every bump and vibration becomes more noticeable, and the added mass of an EV makes controlling body motion more challenging. At the same time the shift towards software-defined vehicles is accelerating the need for digitally controlled suspension that can be integrated and updated easily.